● OPEN TO WORK — AVAILABLE IMMEDIATELY

Berry James

// GRADUATE AI ENGINEER & ROBOTICS SPECIALIST

MSc Robotics & AI graduate building end-to-end intelligent systems — from a 94.17%-accurate CNN human-detection model to a fully autonomous SLAM navigation stack. Currently a Research Intern at the Eureka Robotics Centre, developing safety-critical NLP for human–robot interaction.

CARDIFF, UK / MSC ROBOTICS & AI — CARDIFF MET / RESEARCH INTERN @ EUREKA ROBOTICS CENTRE
01 // PROJECTS

Selected Work

MSC 2025 — 2026
TurtleBot3 robot platform logo
P-01 · AUTONOMOUS NAVIGATION

TurtleBot3 Smart-Office Navigation Stack

Complete ROS 2 autonomy pipeline — SLAM mapping, A* global and DWA local planning — with a real-time human-detection module for context-aware behaviour, validated across multiple Gazebo scenarios.

ROS 2 Gazebo SLAM A* / DWA Python
READ MORE →
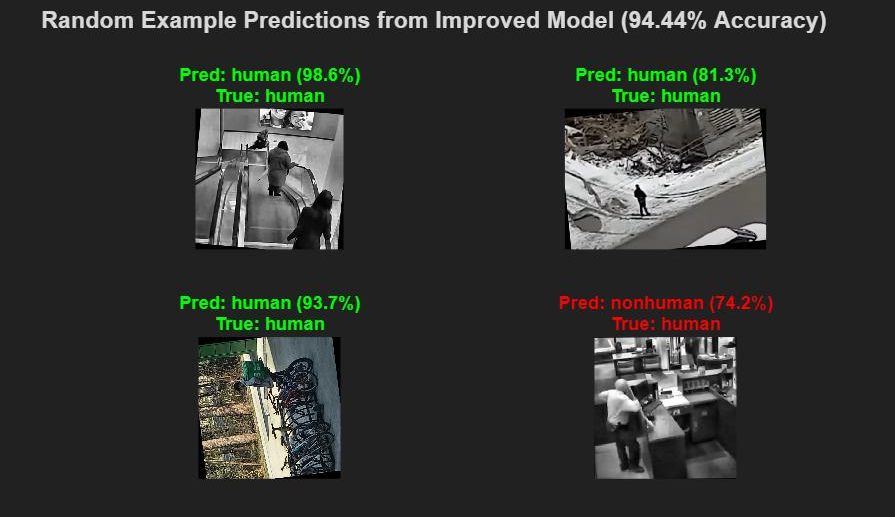
Grid of human/non-human CNN predictions at 94.17% accuracy
P-02 · COMPUTER VISION

Human Detection CNN — 94.17% Accuracy

ResNet-18 fine-tuned for human/non-human classification on a custom dataset expanded with low-light augmentation; evaluated with precision, recall and F1, and designed for lightweight deployment on mobile robots.

ResNet-18 Transfer Learning MATLAB Data Augmentation
READ MORE →
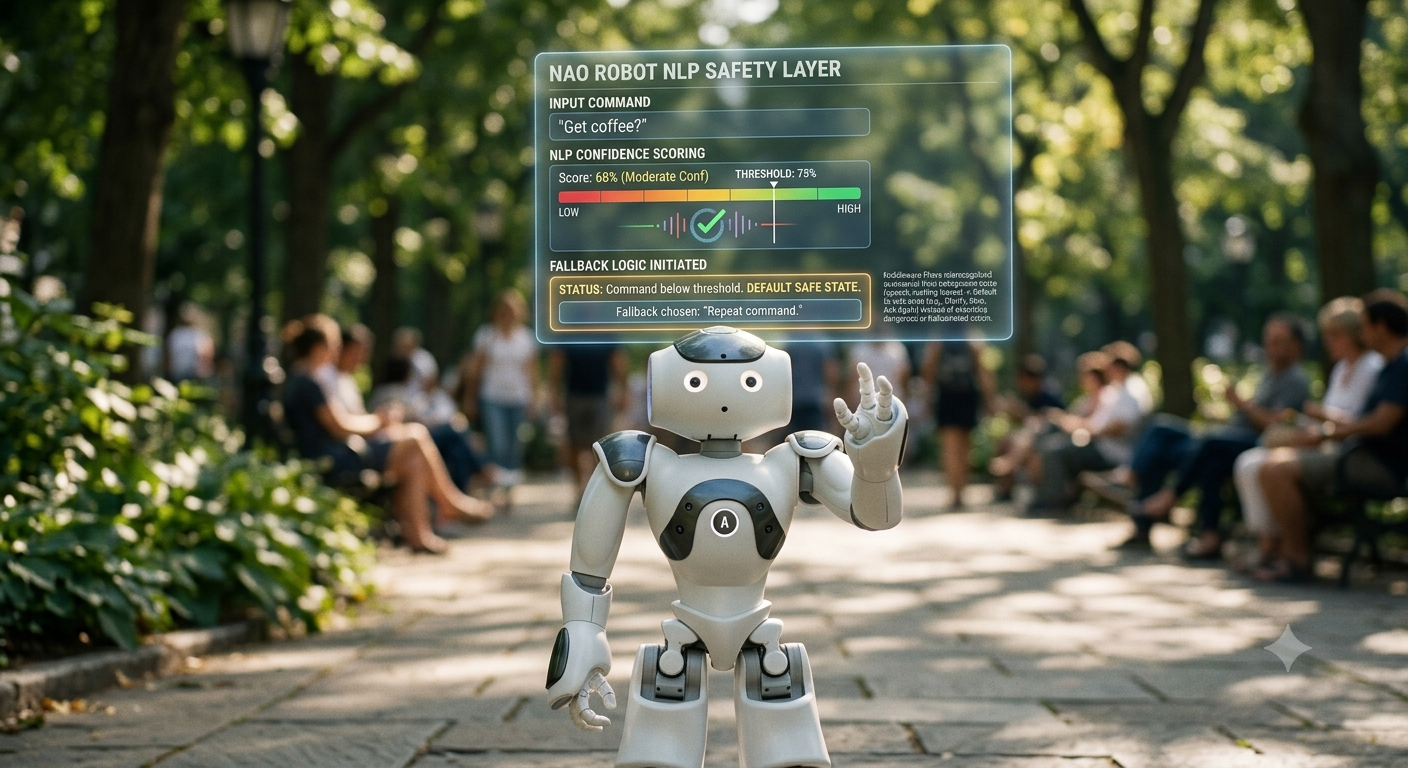
NAO humanoid robot with an NLP confidence-scoring safety-layer overlay
P-03 · MSC DISSERTATION

Noise-Resilient NLP Safety Layer

Safety middleware that confidence-scores NLP outputs and applies threshold + fallback logic, so robots default to a safe state instead of executing misrecognised or hallucinated commands. Publication potential.

Python NLP Confidence Scoring Robot Safety
READ MORE →
Hybrid Model Switcher MCP — logo lockup
P-04 · OPEN-SOURCE TOOLING ● LATEST BUILD

Hybrid Model Switcher MCP

An open-source MCP routing proxy that lets Claude Desktop call locally-hosted Ollama models and translates Anthropic-style payloads through LiteLLM, keeping model-routing state ready for a future desktop companion UI — with tools to discover local models, select a route, forward prompts to Ollama, and delegate back via sampling.

MCP Ollama LiteLLM Anthropic API Python Claude Desktop
VIEW REPO ↗
02 // ABOUT

From Silicon to Servo

I came to AI from the systems side. A Computer Science Engineering degree — algorithms, operating systems, embedded C — and a full-stack Python internship taught me to ship software that survives contact with real users and real hardware.

My MSc in Robotics & AI at Cardiff Met put that foundation to work: training and evaluating deep-learning models, building ROS 2 autonomy stacks, and programming NAO humanoids for assistive physiotherapy. Now, at the Eureka Robotics Centre, I research how robots can act safely when their language models are uncertain — the messy, critical space where models meet motors.

MSC ROBOTICS & AI — 2026 B.TECH COMPUTER SCIENCE — 2024
MACHINE LEARNING & AI
PyTorch TensorFlow CNNs YOLO NLP MATLAB
ROBOTICS
ROS 2 Gazebo SLAM Path Planning TurtleBot3 NAO
SYSTEMS & WEB
Python C++ SQL Django / Flask REST APIs Git Linux
03 // SERVICE MENU

Production-Grade Web Development

FIXED SCOPE · GBP

Freelance builds using the same engineering rigour I bring to research — semantic markup, measurable performance, and a clean handoff to a live URL.

01 // ESSENTIAL LAUNCH £47 FOR SOLOPRENEURS & CREATORS
✓Single-page semantic HTML/CSS
✓Lightning-fast loading speeds
✓Deployment assistance (Netlify/Vercel)
✓Mobile-responsive layout
SELECT PLAN →
03 // FULL-STACK BESPOKE £199 – £499 FOR STARTUPS & COMMERCIAL E-COMMERCE
✓Everything in Premium UI/UX
✓Custom domain setup & SSL certification
✓3 months of managed maintenance
✓Advanced features (Forms, CMS, or Analytics)
SELECT PLAN →